BaseGeom Class Reference
Base class for GL-renderable geoms.
More...
#include <BaseGeom.hh>
Inheritance diagram for BaseGeom:
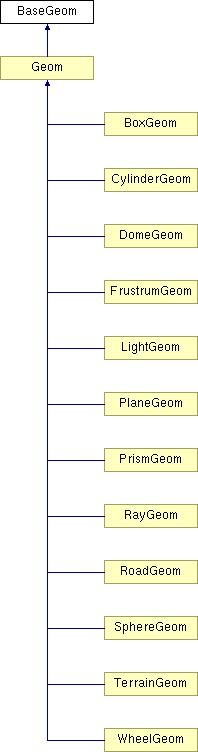 List of all members.
Detailed Description
Base class for GL-renderable geoms.
BaseGeom and Geom are the base classes for all physical geometric objects; BaseGeom encapsulates the mass and collision characteritics, while Geom encapsulated the visual appearance.
Constructor & Destructor Documentation
| BaseGeom::BaseGeom |
( |
dSpaceID |
spaceId |
) |
|
|
| BaseGeom::~BaseGeom |
( |
|
) |
[virtual] |
|
Member Function Documentation
| void BaseGeom::SetGeom |
( |
Body * |
body, |
|
|
dGeomID |
geomId, |
|
|
dMass * |
mass, |
|
|
bool |
placeable |
|
) |
|
|
|
|
Set the encapsulated geometry object.
|
| void BaseGeom::SetExtraRotation |
( |
GzQuatern |
rot |
) |
[protected] |
|
| dGeomID BaseGeom::GetTransId |
( |
|
) |
const |
|
| dGeomID BaseGeom::GetGeomId |
( |
|
) |
const |
|
| void BaseGeom::SetCategoryBits |
( |
uint |
bits |
) |
|
|
| void BaseGeom::SetCollideBits |
( |
uint |
bits |
) |
|
|
| void BaseGeom::SetRelativePose |
( |
GzPose |
pose, |
|
|
bool |
updateCoM = true |
|
) |
[virtual] |
|
|
|
Set object pose (relative to body).
Reimplemented in RayGeom. |
| GzPose BaseGeom::GetRelativePose |
( |
|
) |
const [virtual] |
|
|
|
Get object pose (relative to body).
Reimplemented in RayGeom. |
| GzPose BaseGeom::GetPose |
( |
|
) |
const |
|
|
|
Get object pose (global coord).
|
| void BaseGeom::SetRelativePosition |
( |
GzVector |
pos |
) |
|
|
|
|
Set the relative position (without changing the rotation).
|
| void BaseGeom::SetRelativeRotation |
( |
GzQuatern |
rot |
) |
|
|
|
|
Set the relative rotation (without changing the position).
|
| void BaseGeom::SetHardness |
( |
double |
kp, |
|
|
double |
kd |
|
) |
|
|
|
|
Set surface hardness parameters for contact joints.
- Parameters:
-
| kp | Elastic spring constant |
| kd | Damping constant |
|
| void BaseGeom::SetFriction |
( |
double |
mu1, |
|
|
double |
mu2 |
|
) |
|
|
|
|
Set friction coefficients.
- Parameters:
-
| mu1 | Coefficient in direction 1 |
| mu2 | Coefficient in direction 2 |
|
| void BaseGeom::SetBounce |
( |
double |
bounce |
) |
|
|
| void BaseGeom::SetSlip1 |
( |
double |
slip |
) |
|
|
| void BaseGeom::SetSlip2 |
( |
double |
slip |
) |
|
|
| double BaseGeom::GetBounce |
( |
|
) |
const |
|
| double BaseGeom::GetSlip1 |
( |
|
) |
const |
|
| double BaseGeom::GetSlip2 |
( |
|
) |
const |
|
| void BaseGeom::SetMass |
( |
double |
m |
) |
|
|
| const dMass * BaseGeom::GetBodyMassMatrix |
( |
|
) |
|
|
Friends And Related Function Documentation
friend class World [friend] |
|
Member Data Documentation
The documentation for this class was generated from the following files:
|
Last updated 12 September 2005 21:38:45
|